 Click to enlarge
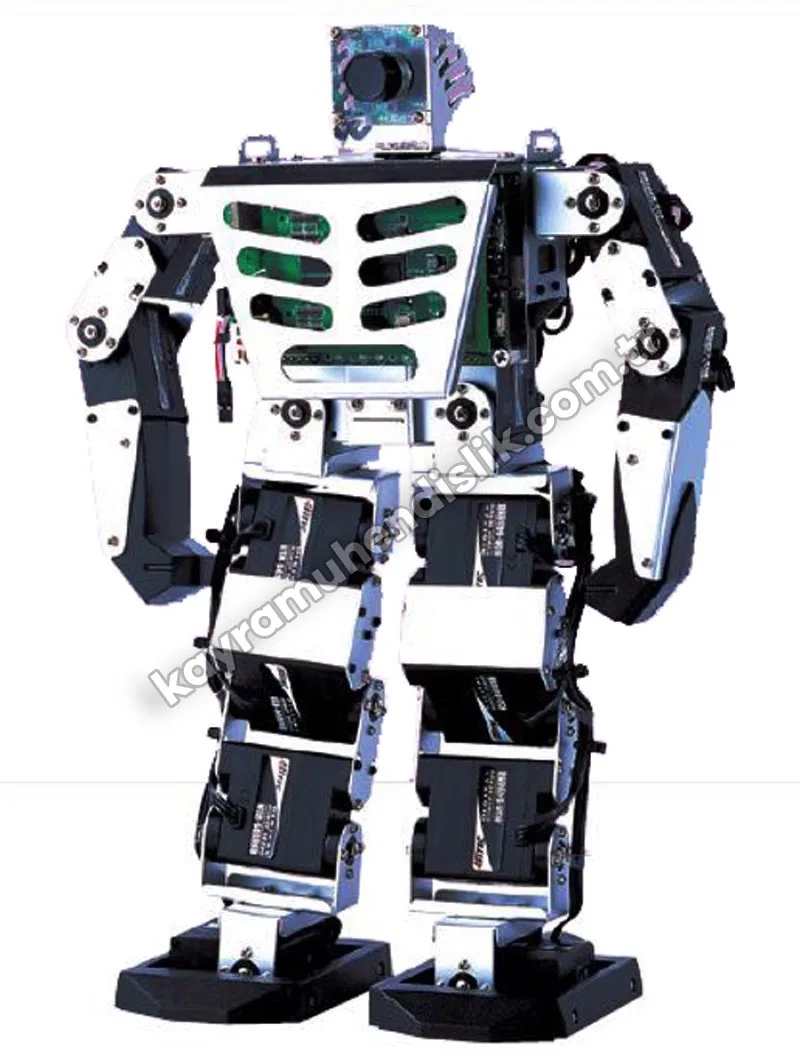
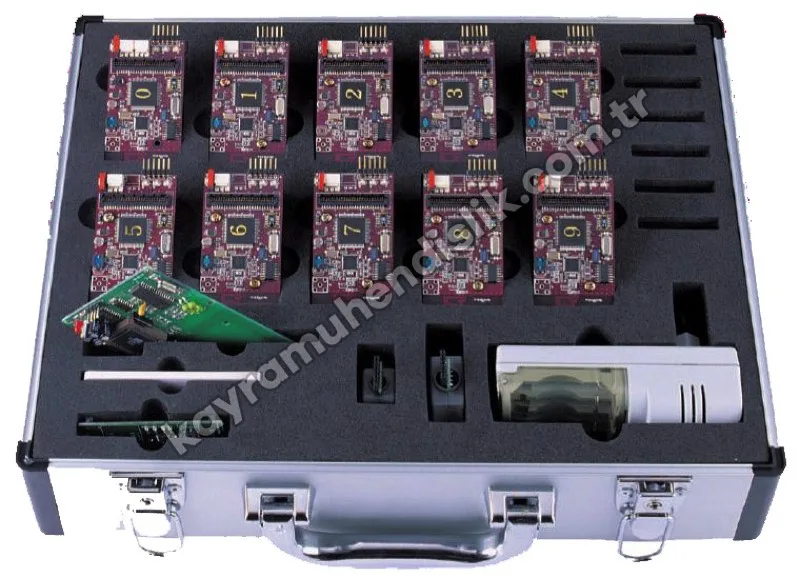
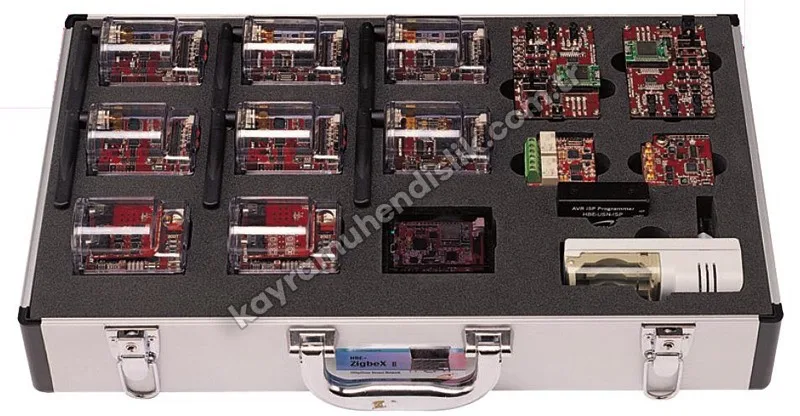
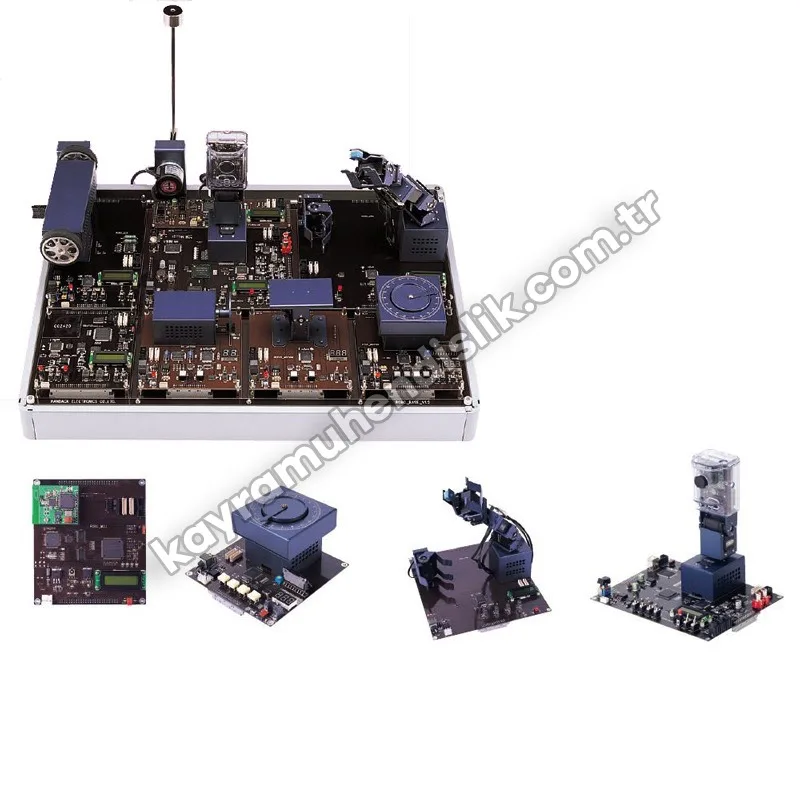
RoboMotor KE10020
Ask About This ProductDescription
Features
- Possibility to learn the robot's motor drivers and sensors systematically and step by step
- Learning basic motor control and sensor control
- Learning motor control and sensor control in depth
- Applying what has been learned
- Possibility to work on all the motors and sensors used in robot systems
- Encoder DC geared motor, servo motor, stepper motor
- Wheel drive body connected between the encoder DC geared motor and the servo motor
- Pan/tilt control using a serial servo motor
- Cliff, tilt, pressure and ultrasonic sensors, CCD camera, microphone, loudspeaker, odour sensor
- High-resolution encoder DC geared motor, high-sensitivity angular encoder
- Possibility to run manual control and automatic control via programming in parallel, to learn motor driver and sensor principles
- Practising basic motor principles through manual control of DC, servo and stepper motors
- Practising automatic motor control programming based on motor principles
- Practising manual and program control for forward/reverse drive, angle, torque, tilt and distance control
- Practising manual and program control for visual, olfactory and tactile sensing
- Possibility to practise alternatively with a general-purpose microcontroller (ATmega128) and a DSP for precise intelligent control
- Practising central processing and module processing via the main controller and module controllers
- Parallel application of ATmega128
- Possibility to work on visual, auditory and tactile control
- Human figure detection
- Acquiring images and sound from a computer via a USB 2.0 (480 Mbps) interface
- Acquiring and controlling images using a video input processor
- Acquiring 2-channel sound and controlling the loudspeaker output using an audio codec
- Detecting and controlling touch using a pressure sensor
- Possibility to control the robot remotely using IrDA/USN
- Remote control using IrDA
- Remote control using the ZigbeX part (option)
- Possibility to practise intelligent control algorithms using an inverted pendulum
- Practising the inverted pendulum using a high-performance DC geared motor (24 V, 2000 rpm, 1.9 kg-cm, 1/4 gear ratio) and an angular encoder
- Linear guide and pendulum device converting circular motion into linear motion
Main module names
| 1. CPU module | ATmega128-8AC |
| 2. DC motor module | RB-35GM, cliff sensor |
| 3. Servo motor module | HSR-8498HB, tilt sensor |
| 4. Stepper motor module | SST42D1100, angle sensor |
| 5. Wheel drive module | RB-35GM*2 pcs, HSR-8498HB |
| 6. Pan/tilt module | AX-12*2 pcs, camera, loudspeaker, microphone, odour sensor |
| 7. Arm module | HSR-8498HB*5 pcs, pressure sensor |
| 8. Pendulum and ultrasonic module | DS4573+IG42, angular encoder, ultrasonic sensor |
Experiment Contents
Introduction to control systems | 1. Control systems |
Introduction to control systems | 2. Robot systems |
Fundamentals of intelligent robot system control | 3. Microcontroller principles |
Fundamentals of intelligent robot system control | 4. Signal and system principles |
Fundamentals of intelligent robot system control | 5. Robot control principles |
Fundamentals of intelligent robot system control | 6. AVR microcontroller development environment |
Fundamentals of intelligent robot system control | 7. GPIO and interrupt I/O control |
Fundamentals of intelligent robot system control | 8. DC motor control and sensors |
Fundamentals of intelligent robot system control | 9. Servo motor control and sensors |
Fundamentals of intelligent robot system control | 10. Stepper motor control |
Fundamentals of intelligent robot system control | 11. Wheel control and sensors |
Fundamentals of intelligent robot system control | 12. Robo-head control and sensors |
Fundamentals of intelligent robot system control | 13. Robo-arm control and sensors |
Fundamentals of intelligent robot system control | 14. Robo pan/tilt control and sensors |
Ek | Appendix A: Introduction to RoboMotor |
Delivery and Installation
Before shipment, our products are inspected and packed in special impact-resistant packaging, and are delivered safely to every province of Türkiye.
Installation: In laboratory and classroom projects, installation and commissioning after delivery are carried out by our expert team.
Training and support: User training and after-sales technical support are provided for experiment sets and simulators.