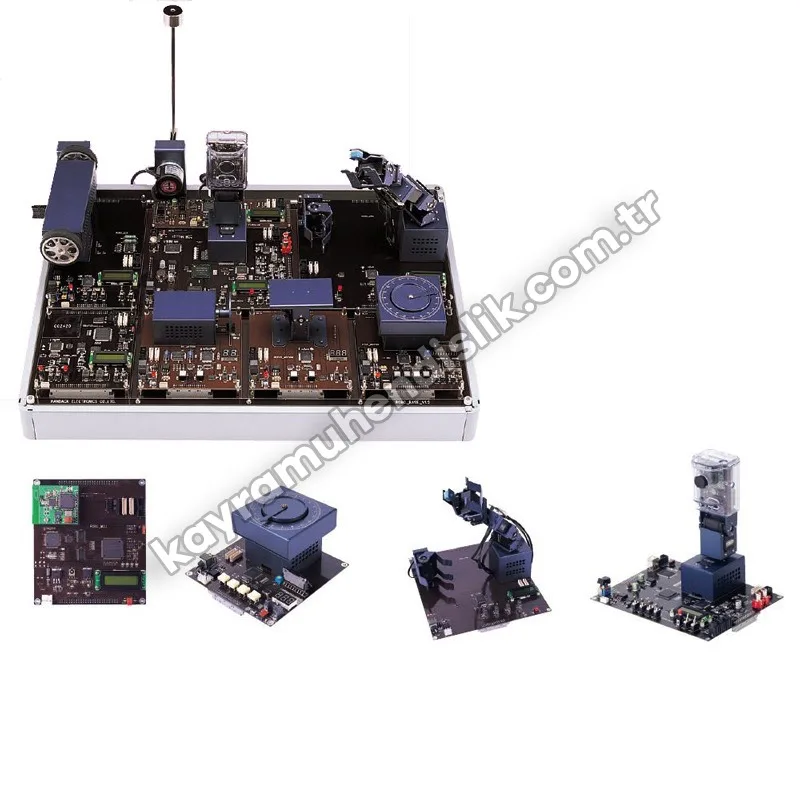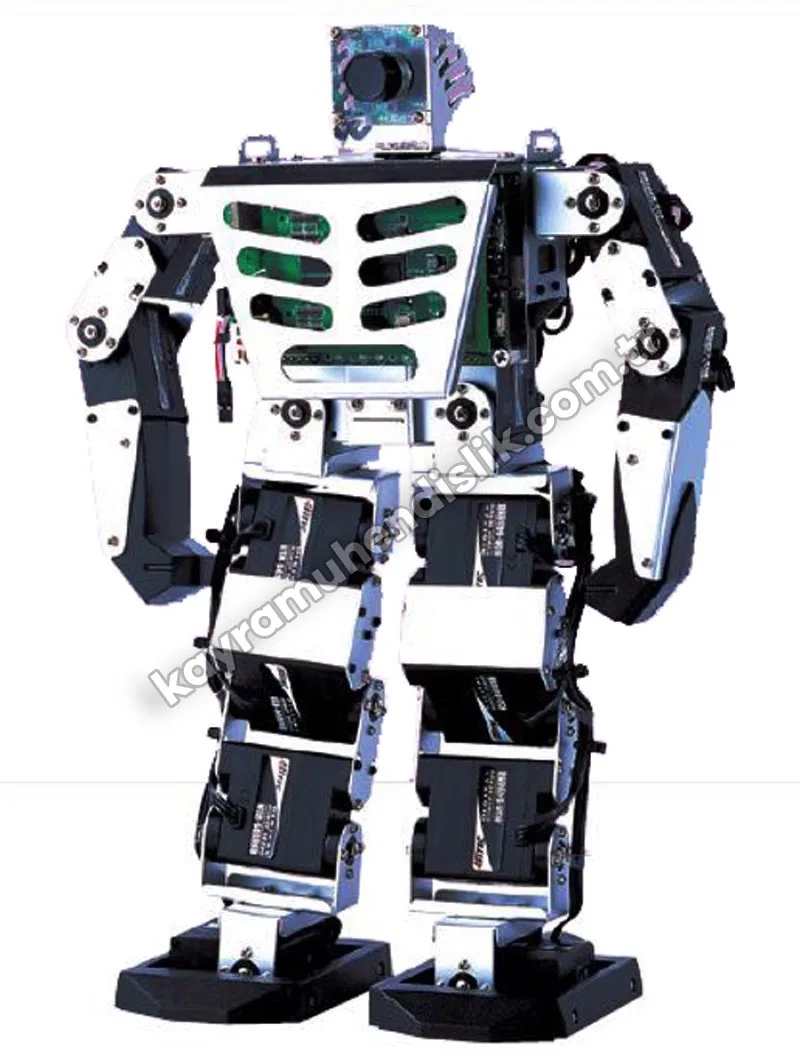
 Click to enlarge
Erobo-Tank KE10060
Ask About This ProductDescription
Introduction
The intelligence and mobility of home automation robots, such as cleaning robots, have generally risen sharply in recent times. Even so, many mobile robots can show their mobility only on flat ground, because of their body shape and fixed wheels.
Erobo-Tank, by contrast, is an advanced smart tracked tank robot with 1 joints and 4 arms, with many advantages in performing many movements, keeping its balance and overcoming obstacles. Equipped with various sensors, it achieves body movement and determines its position. It also has a real-time wireless control function. It should be fitted with the ZigbeX part and sensor modules for wireless sensor network applications.
Erobo-Tank lets you carry out laboratory experiments on robot motor and sensor control programming with four ATmega128 microcontrollers. Optionally, with KROBO, which carries an ARM9-based processor board and robot stereo cameras, an autonomous robot project with vision capability can be carried out.
Features
- Smart tracked mobile robot system
- Easy-to-learn, easy-to-use 8-bit ATmega128 MCU microcontroller
- High-performance parallel processing platform using 4 sets of 8-bit microcontrollers
- PSD and ultrasonic sensors for obstacle detection
- Tilt, acceleration and magnetic compass sensors for controlling robotic movements
- GPS module for robot position control
- Encoders on all 6 DC motors for full motion control
- Flexible mobility with a track set and 4 arms
- Real-time control with the USN ZigbeX part and IR sensor module
- Advanced smart robot system with sound and image awareness in combination with KROBO (option)
- Dimensions: 472x590x110 mm
- Power: 11.1 V lithium polymer battery
- Sample program support for basic laboratory experiments
- Standard training program, user manual, user training support
Hardware details
| Microcontroller | ATmega128 (program memory 128 KB, ADC 10-bit 8 ch), 4 pcs |
| Memory | 32K 8-bit low-power CMOS static RAM |
| Motor | DC 12 V planetary gear motor (reduction ratio: 1/212) & encoder, 6 pcs |
| RF interface | ZigbeX USN part & IR module |
| Basic sensors | PSD, GPS, accelerometer, voltage monitor, temperature, magnetic compass, ultrasonic |
| Power | 11.1 V 1800 mAh lithium polymer battery |
| Size | 472x590x110mm |
Experiment Contents
| Mobile robot system (Erobo-Tank) |
| Simple movements of Erobo-Tank |
| Arm angle control |
| Arm speed control |
| Obstacle avoidance with the PSD sensor |
| Obstacle avoidance using the ultrasonic sensor |
| Balancing with the tilt sensor |
| Robot movement with the magnetic compass |
| Wireless communication with the Zigbee module |
| Operating Erobo-Tank with the Zigbee module |
| Estimating robot position with data fusion |
| Erobo-Tank movement using location information |
| Driving with obstacle avoidance using data fusion sensors |
| Overcoming vertical obstacles using data fusion sensors |
Delivery and Installation
Before shipment, our products are inspected and packed in special impact-resistant packaging, and are delivered safely to every province of Türkiye.
Installation: In laboratory and classroom projects, installation and commissioning after delivery are carried out by our expert team.
Training and support: User training and after-sales technical support are provided for experiment sets and simulators.