 Click to enlarge
RoboCar-Vision KE10030
Ask About This ProductDescription
Features
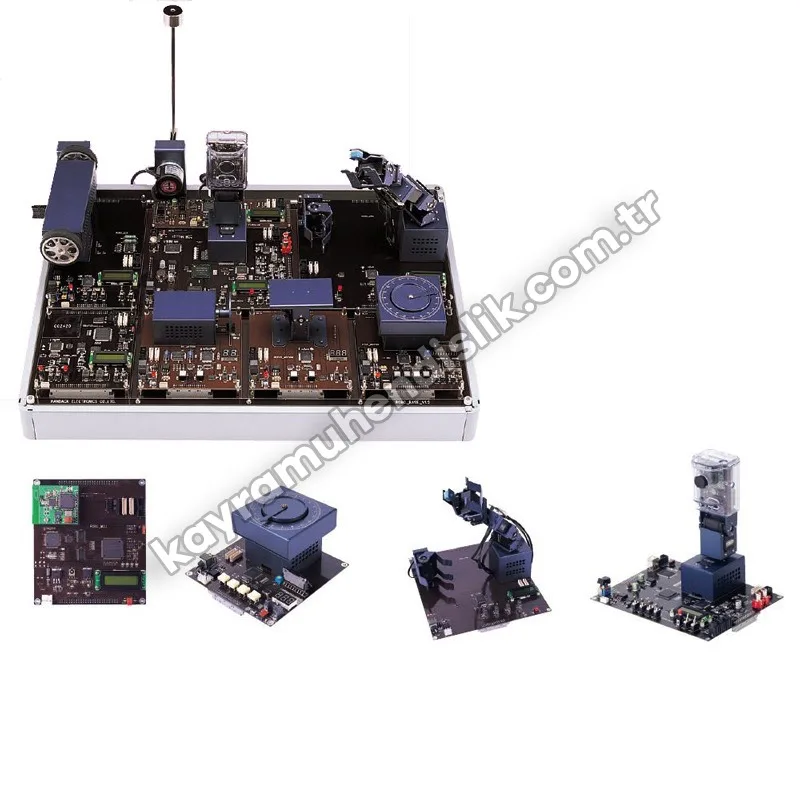
- Designed for training in basic robot actuators and embedded microprocessor (ATmega128) applications for sensor signal processing and actuator control
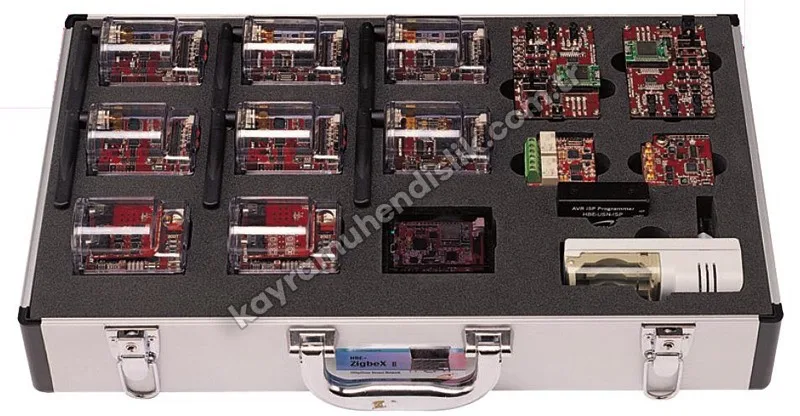
- Development of robot image processing and view-angle control algorithms using a camera with pan/tilt actuators and two-way wireless communication
- Includes various sensors such as ultrasonic, infrared, accelerometer and photosensor for robot actuator control experiments.
- Image processing for smart mobile robot applications using wireless vision solutions
Technical Specifications
| ATmega128L | 8-bit AVR, 128 KB microcontroller, main control |
| ATmega8L |
8-bit AVR, 8 KB microcontroller, voltmeter control |
| L298P | DC drive motor up to 4 A |
| Horizontal/vertical | Digital packet communication, remote control |
| RF communication | 2.4G - 2.5G selectable frequency |
| Camera | VGA CMOS image sensor, 30 fps |
| USB, RS232 | USB Full Speed, RS232 (9600- 115200 bps) |
| Image format | JPEG 20 fps, 160-120 |
| Ultrasonic sensor | 40.0 ± 0.5 kHz frequency, 2.0 bandwidth, 2 pcs |
| Accelerometer sensor | Dual-axis accelerometer sensor, 1 pcs, duty cycle |
| PSD sensor | Distance-measuring sensors, 1 pcs, 10-80 cm |
| Phototransistor | 8-group infrared beam sensor |
| Motors | Geared DC motor, 2 pcs; geared DC motor with encoder, 2 pcs |
| Buzzer | 5 V buzzer input, 1 pcs |
| LED |
10 mm high-brightness LEDs: white 2 pcs, red 2 pcs |
| 7-segment display | Voltmeter display, 3 digits, 1 pcs |
| Regulator | +11.1 V DC input, DC output: +5 V, +3.3 V |
| Battery | +11.1 V, 5200 mA lithium-ion |
| Charger and adapter | +12.6 V, 1.2 A battery charger |
Experiment Contents
| 1. Robot vision - overview |
| 2. Development environment |
| 3. Building a vision project |
| 4. Basic programming |
| 5. Output device control |
| 6. Input device measurement |
| 7. Remote control based on video data |
| 8. Image processing |
| 9. Face tracking |
| 10. Colour recognition |
| 11. Shape recognition |
| 12. Driving with an infrared sensor and camera |
Delivery and Installation
Before shipment, our products are inspected and packed in special impact-resistant packaging, and are delivered safely to every province of Türkiye.
Installation: In laboratory and classroom projects, installation and commissioning after delivery are carried out by our expert team.
Training and support: User training and after-sales technical support are provided for experiment sets and simulators.